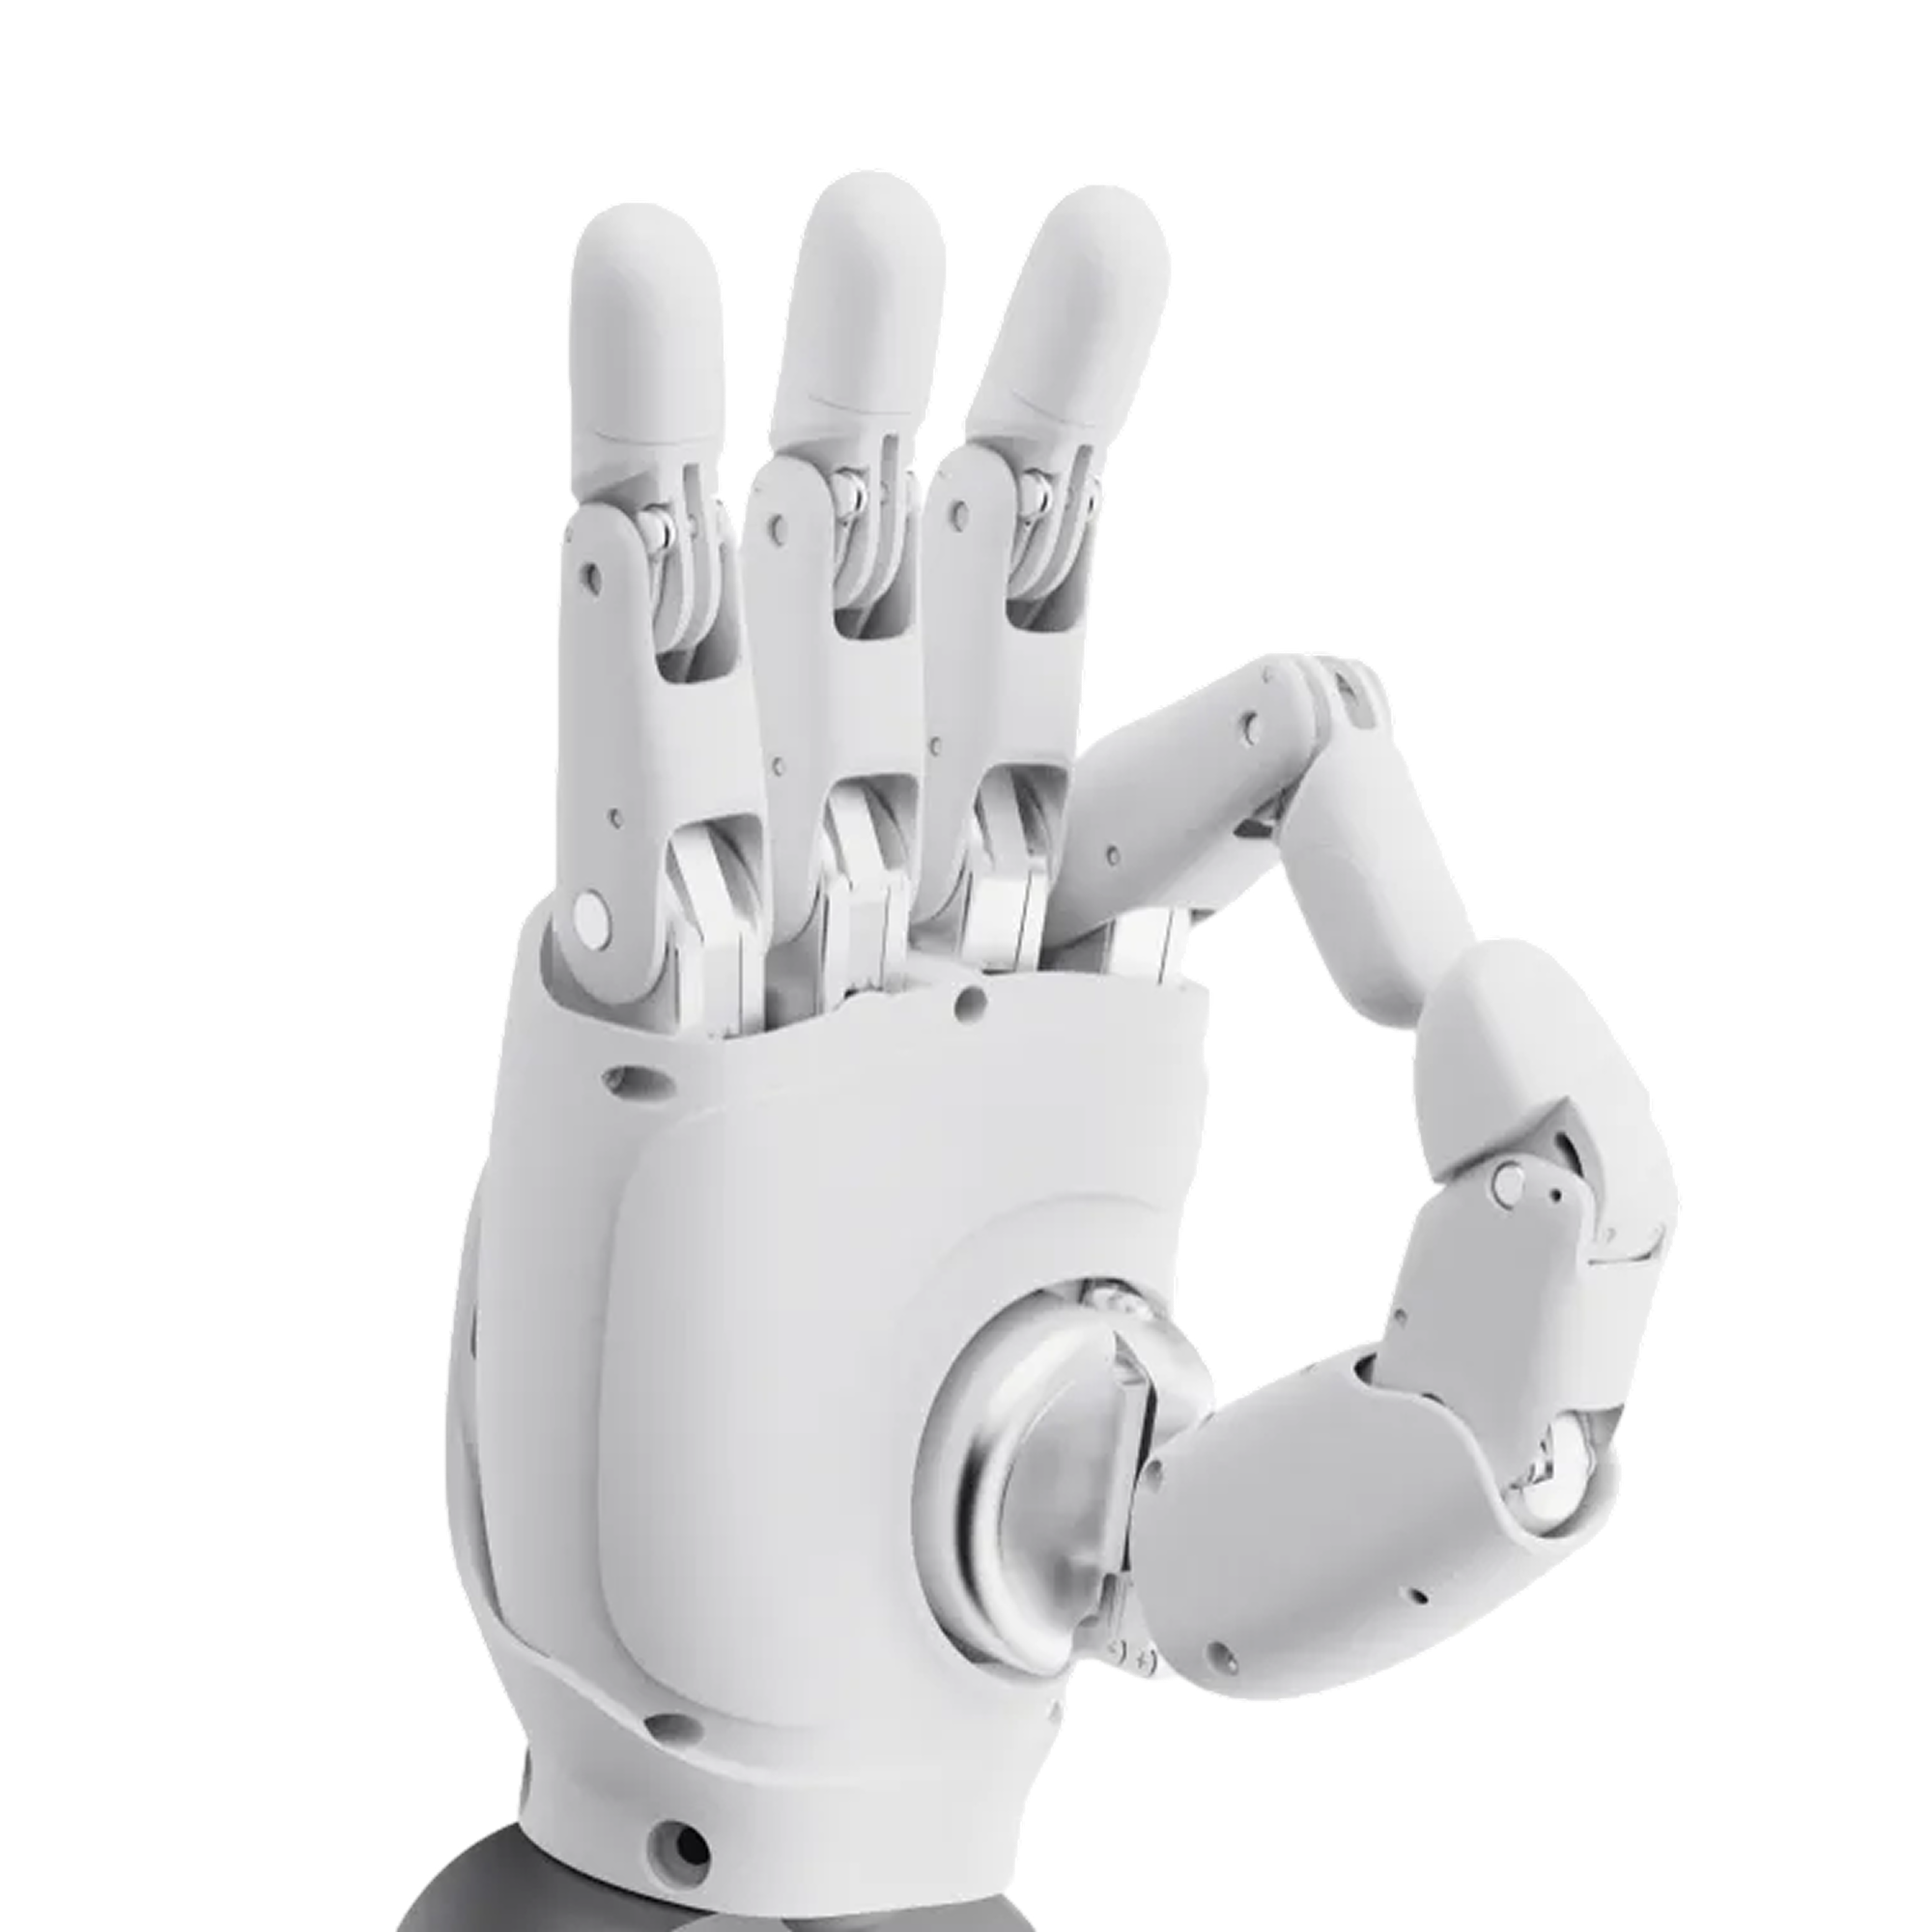
Gripping matched to the object.
End-effector selection starts with the object’s size, material, weight and required movement. Include the hand or gripper’s own weight when calculating the total arm load.
 Robotics
Manufacturer illustrations may show optional equipment. The quotation defines the supplied configuration.
A compact dexterous hand for humanoid gestures and light object manipulation.
Left or right hand: 4,420 USD
Both hands: 8,840 USD
The price is indicative.
Availability and configuration are agreed individually.
End-effector selection starts with the object’s size, material, weight and required movement. Include the hand or gripper’s own weight when calculating the total arm load.
Force control helps adapt the grip to the application. Hand control modes are selected for the object and task; tactile feedback is available only on the variant equipped with the relevant sensors.

Successful gripping requires calibration and control settings as well as mechanical integration. Prototyping with the actual objects verifies grip stability and the available range of motion.

Separate chains form the index, middle, ring and little fingers.
Proximal and distal interphalangeal joints (PIP, DIP) allow the fingers to curl.
Joints near the finger bases support sideways opening and closing.
The thumb combines flexion, abduction and rotation.
A palm-mounted pivot enables opposing grasp positions.
Manufacturer specifications and measurement conditions, organised by topic.
Source: AGIBOT ↗
Compatibility must be checked against the selected robot and adapter.
Actual performance depends on the environment, load, software and configuration. Maximum values may reflect different test conditions and may not be achievable simultaneously.
The confirmed quotation itemises the equipment and licences included in the delivery. Illustrations may show optional accessories.
Software, accessories and deployment requirements are agreed for the selected application.

Create gestures and simple activities such as rock–paper–scissors using suitable control software.

Pick up and pass small objects within the hand’s load and grasping limits.

Test paper and document handling with a compatible robot arm and controller.

Study grasping strategies, motion planning and vision-guided object handling in a laboratory.

Develop experiments with compatible tracking gloves or other control devices; hardware add-ons and integration are separate.
It is designed for expressive gestures, interactive demonstrations, light-object handling, research and education.
Use the manufacturer’s 3D model to check mounting geometry, then verify the host robot’s control interface before integration.
Control options include computer commands, ROS and Python. Teleoperation requires suitable additional devices and integration.
The base interface is 58 mm in diameter and requires 10 mm operating clearance. This version weighs approximately 0.5 kg.
Product data and manufacturer images: AGIBOT. For custom solution packages, the reference describes the base platform.
We help select the right model, equipment and services.